A smooth quadratic reduction with parameters
This companion proves a signed quadratic normal form with smooth parameters, its critical-point Jacobian and the finite-chart consequence for compact parameter sets. Two exact families illustrate curved coordinates, zero coordinate pivots and the limitations of determinant bounds.
Mathematical sources: Jiří Lebl, Basic Analysis II, theorem numbering from version 6.3 (15 May 2026), gives the inverse theorem and proof and the implicit theorem and proof, Theorems 8.5.1 and 8.5.6. Guillemin–Sternberg’s 13 January 2010 author draft, §13.14.3, pp. 455–457, presents the classical Morse lemma and its smooth parameter variant. The proof here uses scalar elimination, the smooth inverse upgrade and the integral Taylor formula.
The programme proof index locates the local arguments; the human-proof references identify external statements and proofs, which retain their own terms. The finite-dimensional companion gives P1–P5; the compact-integral companion gives mixed derivatives and parameter integration. Gaussian and quadratic arguments are in the analytic module.
Original programme exposition: CC0 to the extent rights exist. Cited human works are external mathematical sources and retain their own terms.
M1. Parameter Morse lemma and its Jacobian
Let U⊂Rn and S⊂Rp be open, and
let ϕ∈C∞(U×S;R). Suppose
Dxϕ(x0,s0)=0,H0=Dx2ϕ(x0,s0) is invertible.
There are neighbourhoods of s0 and of z=0, a smooth critical
branch xc(s), and a smooth map F(z,s) such that for each
nearby s, z↦F(z,s) is a local diffeomorphism and
F(0,s)=xc(s),ϕ(F(z,s),s)=c(s)+21j=1∑nσjzj2,c(s)=ϕ(xc(s),s),σj∈{1,−1}.(M1.1)
The signs are independent of s on this neighbourhood. If
H(s)=Dx2ϕ(xc(s),s), then
j∑σj=sgnH(s),∣detDzF(0,s)∣=∣detH(s)∣−1/2.(M1.2)
Proof inputs. The freely accessible C1 inverse and implicit proofs linked above supply the base theorems. Their smooth parameter upgrade P3, matrix inverse P2, Schur calculation P4 and congruence and determinant argument P5 are written locally. The mixed-partial identity P11.2, Taylor formula P12.6 and joint parameter integration P12.7 give the differential and integral steps. The positive square root P8 supplies existence and smoothness; finite compactness supplies the compact-parameter step.
For n=0, the coordinate space is a singleton. Take xc(s)=x0,
F(0,s)=x0, and c(s)=ϕ(x0,s). The quadratic sum and
signature are 0, while the empty determinant and its Jacobian factor are 1.
This proves all assertions in that case. In the proof below, n≥1.
Proof: locate and translate the critical point. Apply the implicit
theorem, upgraded by P3, to the smooth map Dxϕ(x,s).
Its derivative in x at (x0,s0) is H0, so there is a
unique smooth branch xc(s) in a sufficiently small fixed product
neighbourhood. Replace x by xc(s)+u and subtract c(s).
The resulting smooth function f(u,s) has
f(0,s)=0, Duf(0,s)=0 and an invertible Hessian for every
nearby s. The last assertion follows by continuity of the determinant
and its nonzero value at s0.
Choose a nonzero scalar pivot. A nonzero symmetric matrix has a vector
with nonzero quadratic value. To verify this without assuming a normal form,
if a diagonal entry is nonzero, use its coordinate vector. If every diagonal
entry is zero, some off-diagonal entry hij is nonzero, and
(ei+ej)TH(ei+ej)=2hij=0. Make a fixed invertible linear
change of variables taking that vector to the first coordinate direction.
Such a change can be constructed by adjoining all coordinate vectors except
one in which the chosen vector has a nonzero component; expansion of the
resulting matrix in that row gives a nonzero determinant. This change is
fixed at s0, so it is smooth in the parameters. After shrinking the
neighbourhood, ∂12f(0,s) stays nonzero with one fixed sign.
Eliminate one variable. Write u=(u1,u′). P3 applied to
∂1f gives a smooth function u1=q(u′,s) for which
∂1f(q(u′,s),u′,s)=0. Since u=0 is critical and the
solution is locally unique, q(0,s)=0. Put
g(u′,s)=f(q(u′,s),u′,s). With v=u1−q(u′,s), the integral
Taylor formula proved in P12.6 gives
f(q(u′,s)+v,u′,s)=g(u′,s)+21v2A(v,u′,s),
A(v,u′,s)=2∫01(1−t)∂12f(q(u′,s)+tv,u′,s)dt.(M1.3)
Shrink the product neighbourhood so that q(u′,s) and
q(u′,s)+v lie in a smaller coordinate interval whose closure stays
inside the phase domain, with the other coordinates fixed. The whole segment
between them then stays in that interval. Specifically apply P12.6 to the function
t↦f(q(u′,s)+tv,u′,s) on [0,1]. Its first derivative
at 0 is zero and its second derivative is
v2∂12f(q(u′,s)+tv,u′,s). This proves (M1.3) for every
sign of v, including zero. The parameter integration is over a fixed
compact interval, so P12.7 proves that A is jointly smooth. No global
improper-integral input from Q1 is needed for this step. At (v,u′)=0,
A(0,0,s)=∂12f(0,s)=0.
Shrink once more so that A is nonzero throughout the neighbourhood
with a single sign σ1. Define
z1=v∣A(v,u′,s)∣.
Its v-derivative at (v,u′)=(0,0) is
∣A(0,0,s)∣>0. Apply P3 to the map
(v,u′,s)↦(z1,u′,s): its derivative is block triangular,
with this nonzero entry and identity blocks, hence invertible. We obtain
a smooth local inverse, jointly in z1,u′,s. In these coordinates,
f=g(u′,s)+σ1z12/2.(M1.4)
In particular the residual function is independent of z1.
Induct with an invertible residual Hessian. The function g has
g(0,s)=0, and its first derivative vanishes at zero: differentiating
the composite contributes only first derivatives of f there. P4
computes its Hessian as the Schur complement of the chosen scalar pivot.
That complement is invertible because the original Hessian is invertible.
For n=1, (M1.4) already completes the construction. For n>1,
apply the same construction to g(u′,s), in n−1 variables and
with the same parameters. Finite induction yields a signed quadratic
form in all n coordinates. At each of the finitely many steps,
the nonzero pivot and the inverse map persist on an open neighbourhood
of the relevant base point. Take preimages of these neighbourhoods under
the preceding continuous coordinate maps, so they are neighbourhoods of
the same original base point. Their finite intersection is still a neighbourhood;
choose smaller product neighbourhoods inside it. Composing the inverse
coordinate maps and the initial translation gives the smooth map F
in (M1.1).
Identify its signature and volume factor. Differentiate (M1.1) twice
in z at zero. Terms containing second derivatives of F are
multiplied by Dxϕ(xc(s),s)=0, so the chain rule reduces to
[DzF(0,s)]TH(s)DzF(0,s)=diag(σ1,…,σn).
P5 gives both the signature identity and the determinant identity
in (M1.2). This also proves local constancy of the Hessian signature
for this critical family; it has not been assumed as an unproved
spectral-continuity assertion. □
M2. The precise compact-parameter consequence
Suppose a smooth critical branch is defined on an open neighbourhood of a
compact parameter set S0, and its Hessian is invertible on S0.
For each point of S0,
M1 supplies a local parameter neighbourhood and a signed Morse chart.
Before selecting the cover, choose around each parameter point a smaller
open parameter neighbourhood with compact closure in its chart domain,
and a smaller coordinate ball with compact closure in the coordinate
domain. These smaller parameter neighbourhoods still cover S0.
P1 and the earlier compactness proofs supply a finite subcover.
On each selected product closure, every fixed finite list of derivatives
of the coordinate map is bounded by the earlier extreme-value theorem.
Its image under (z,s)↦(F(z,s),s) is compact, by the proved
continuous-image theorem, and is contained in the inverse map's open
domain. Derivatives of the inverse are bounded on that compact image by
the same extreme-value theorem. The largest of finitely many bounds is finite.
Thus later stationary-phase estimates can be proved in finitely many local
charts with uniform finite constants. This conclusion does not assert a
single global signed frame, nor a uniform coordinate size for a collection
of phases whose Hessians approach singularity. It also does not itself
construct the partition of unity or identify the clean quotient density;
those are additional steps in the full lesson.
M3. A curved family with an exact signed quadratic chart
For s>−1 put
ϕs(x,y)=21(x−s+y2)2−21(1+s)y2,Fs(z1,z2)=(s+z1−1+sz22,1+sz2).(M3.1)
This is an exact example of M1, not a truncation. The inverse coordinates
are z1=x−s+y2, z2=1+sy, so Fs is a global
smooth diffeomorphism and
ϕs(Fs(z))=(z12−z22)/2,detDFs=(1+s)−1/2.(M3.2)
To check the critical point and Hessian, write u=x−s+y2. Then
∂xϕs=u, ∂yϕs=2yu−(1+s)y.
Both vanish only at (x,y)=(s,0). Differentiating once more gives
D2ϕs=(12y2y2u+4y2−(1+s)),D2ϕs(s,0)=diag(1,−(1+s)).
Its signature is zero and its determinant is −(1+s), which verifies
the Jacobian predicted by (M1.2). The direct derivative of Fs is
upper triangular with diagonal entries 1,(1+s)−1/2, independently
checking that factor. On −1/2≤s≤1/2 these maps have bounded
derivatives of every fixed order on each fixed compact z-set.
As s↓−1, the Hessian loses invertibility and its determinant
factor becomes unbounded, illustrating the limitation in M2.
Indeed, for every B>0, the inequality 0<1+s<B−2 gives
(1+s)−1/2>B, by the positive-root comparison proved in P8.
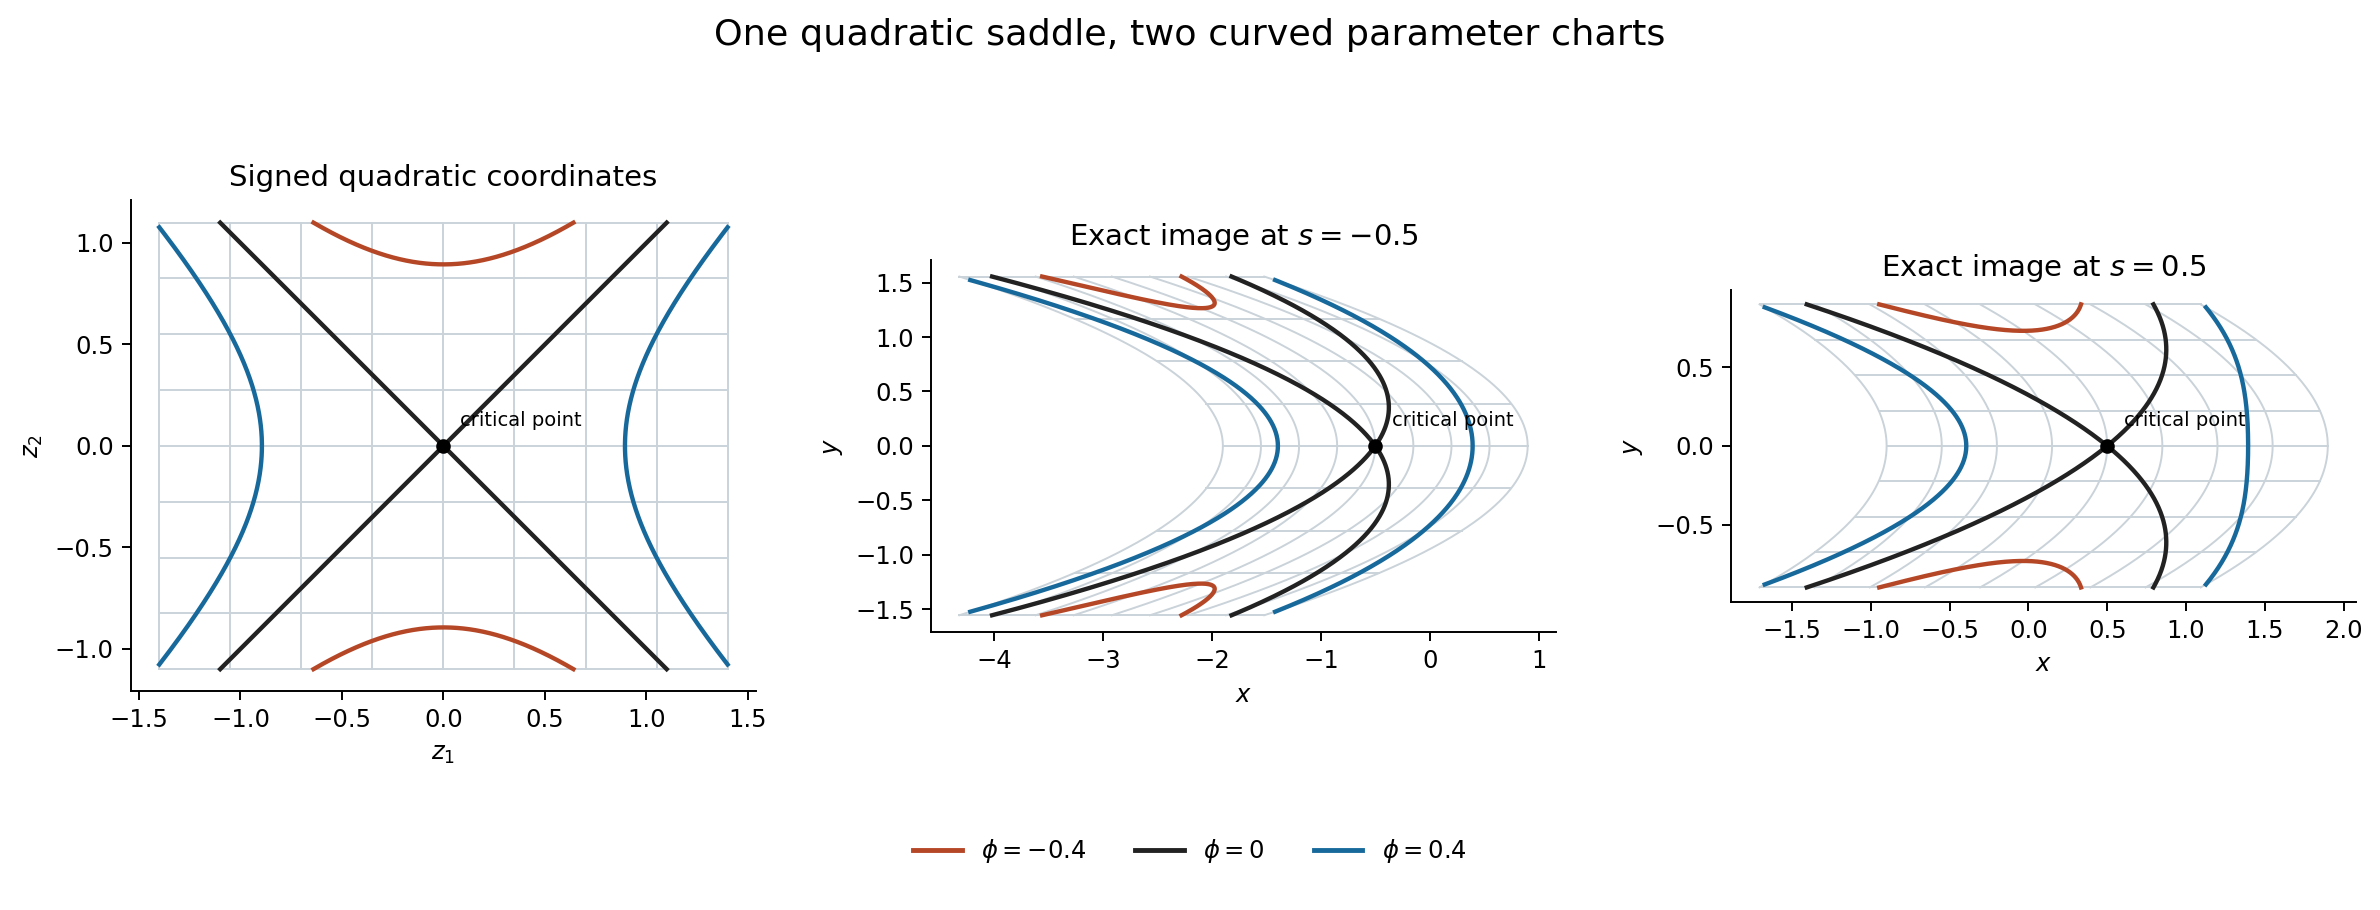
Figure 2. The left panel shows the z-coordinate rectangle
[−1.4,1.4]×[−1.1,1.1]. The other panels show its exact images
under Fs for s=−1/2 and s=1/2. Light curves are images of
the same coordinate grid. The three labelled phase levels are mapped by
(M3.1), so they have exactly the same phase values by (M3.2). The black
point is the critical point, (0,0) in the first panel and (s,0)
in the others. Curves are numerical samples of these exact formulae,
not numerical proofs. Reproducible source: figures/draw_parameter_morse.py.
The example is constructed here from the parameter normal-form mechanism
in M1, with the free human sources identified at the start of this module.
M4. A zero-diagonal pivot and a determinant bound
Exercise. For every real parameter s, consider
ψs(x,y)=xy+2sy2,Hs=(011s),detHs=−1.(M4.1)
Find its critical point and a signed Morse chart. Explain why the two coordinate directions cannot supply the first pivot when s=0, and why a uniform determinant bound does not give uniform chart derivatives on the whole parameter line. Throughout this exercise, ∥D∥2=sup∣z∣=1∣Dz∣ is the Euclidean operator norm.
Solution. The gradient is (y,x+sy), so the only critical point is the origin. At s=0 both diagonal Hessian entries vanish, but (e1+e2)TH0(e1+e2)=2. This is the nonzero direction used in M1. Its quadratic value for general s is 2+s; that particular pivot is suitable near zero and vanishes at s=−2, although the full Hessian is invertible there too.
Put u=x+sy/2 and v=y. Then ψs=uv. Taking u=(z1+z2)/2 and v=(z1−z2)/2 gives the global, jointly smooth chart
Fs(z)=21((1−s/2)z1+(1+s/2)z2, z1−z2),ψs(Fs(z))=21(z12−z22).(M4.2)
Its inverse is z1=(x+(s/2+1)y)/2, z2=(x+(s/2−1)y)/2. Direct expansion gives detDzFs=−1, so its absolute Jacobian agrees with M1.2 for every s. The Hessian has signature zero, since it is congruent to J=diag(1,−1).
There cannot be a uniform first-derivative bound for any such choice of Morse charts over all real s. Indeed, let D be the derivative at zero of any chart with target J. The differentiated normal form gives DTHsD=J. Inverting and multiplying yields
Hs−1=(−s110)=DJDT.
For r=DTe1, the upper-left entry says −s=rTJr, whence ∣s∣≤∣r∣2. The row rT is nonzero because D is invertible. Testing D on the unit vector r/∣r∣ gives a first coordinate equal to ∣r∣, and hence
∥D∥2≥∣r∣≥∣s∣.(M4.3)
For every proposed finite bound B>0, choosing ∣s∣>B2 contradicts it. Thus even the constant value ∣detHs∣=1 is insufficient on a noncompact parameter set. On each compact parameter interval the explicit chart and its inverse do have bounded derivatives of each fixed order on compact coordinate sets, as M2 states.
For the displayed chart write Ds=DzFs=AsR, where As=(10−s/21) and R=2−1/2(111−1) is orthogonal. The matrix AsTAs has determinant 1 and trace 2+s2/4. Its larger eigenvalue is 1+s2/8+∣s∣s2+16/8, by the quadratic formula. Orthogonal diagonalization Q5 shows that the square of the operator norm is this larger eigenvalue. Taking its positive square root gives
∥Ds∥2=4s2+16+∣s∣.(M4.4)
This calculation also fixes the meaning of the plotted norm; it is not an entrywise or Frobenius norm. □
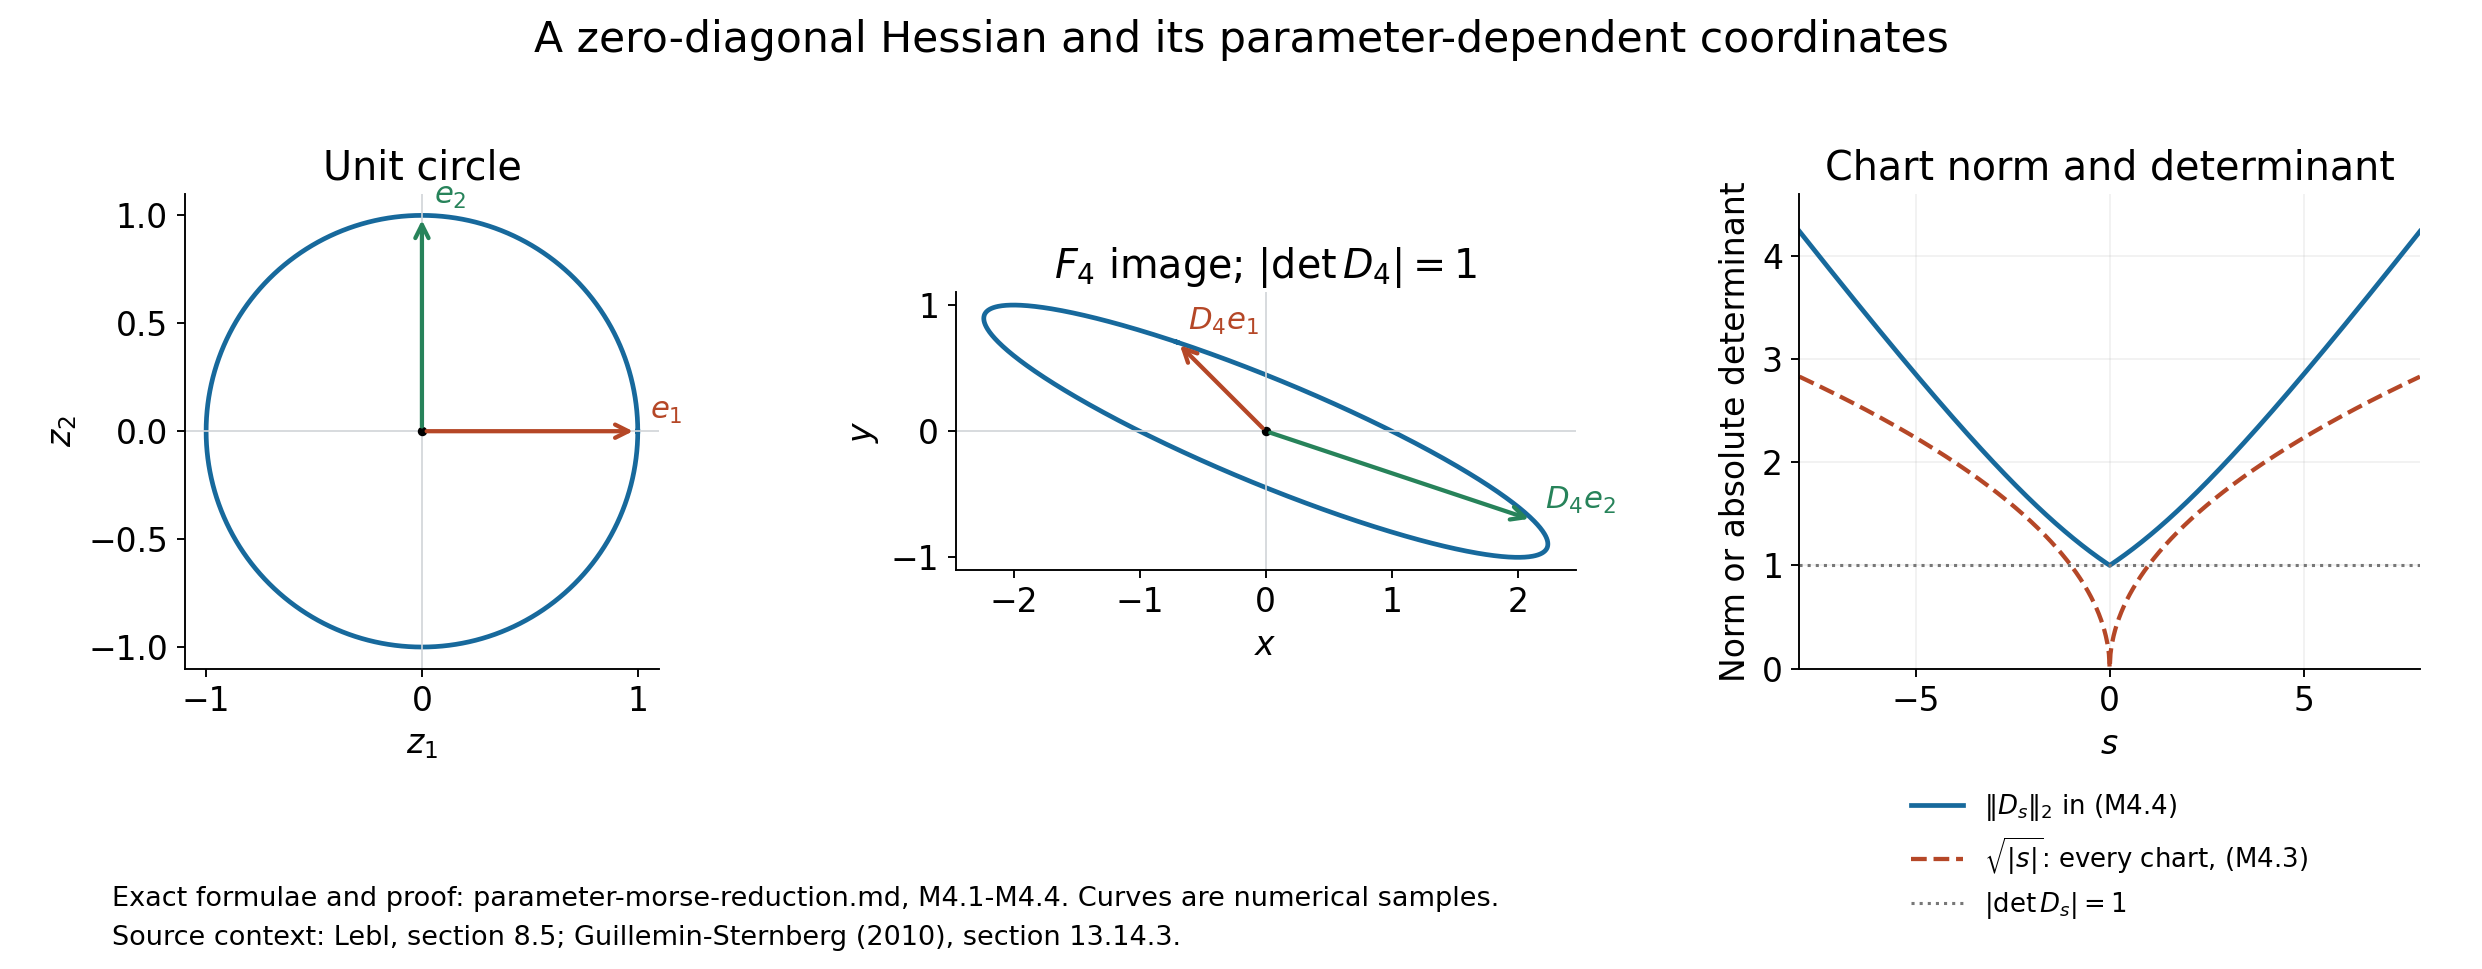
Figure 3. The first two panels show the unit circle and its image under F4, with the coordinate vectors and their images labelled. The last panel plots the exact norm M4.4 of the displayed chart, the lower bound M4.3 valid for every such chart, and the constant absolute Jacobian 1. Its parameter range is [−8,8]. Curves are numerical samples of the exact formulae; the proofs are above. Reproducible source: parameter-morse-pivot-norms.py; vector illustration.
Worked exercise and Figure 3: GPT-6.1 Sol (OpenAI). Original programme contribution: CC0 to the extent rights exist. Human sources and plotting software retain their own terms.